We are now sampling our Robot Dog Joint Module — a 24 V integrated actuator designed specifically for the hip, knee and ankle joints of quadruped robots. The design brief was simple: maximum torque per gram, minimum wiring, and field-tunable control parameters.
Why This Joint Exists
Most off-the-shelf servo modules for quadruped robots are scaled-down industrial servos — they work, but they were designed for stationary industrial axes, not for the shock loads and weight constraints of a walking robot. Our module was designed from the housing up for quadruped duty cycles.
Key Specifications
| Weight | ≤220 g |
| Supply voltage | 24 V DC |
| Rated current | 3.0 A · peak 7.0 A |
| Rated output torque | 3.0 N·m · peak 6.0 N·m |
| Reducer ratio | 10:1 planetary |
| Encoder | Dual magnetic encoders (input + output) |
| Rated speed | ≥120 rpm · no-load ≥300 rpm |
| Operating temperature | −20 °C to +70 °C |
Mechanical Interface
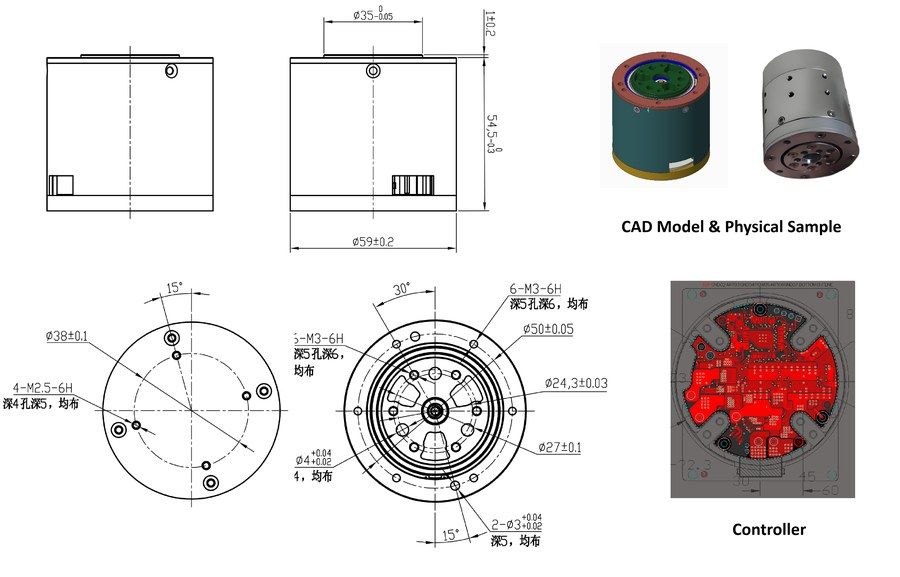
- Standard 8 mm output shaft with optional 6 mm adapter.
- M3 mounting pattern on the housing flange.
- Integrated cable with 300 mm flying lead, Molex Micro-Fit connector on request.
- Sealed to IP54 against dust and light water spray.
Control Interface
- CAN bus (default) or RS485 on request.
- FOC current loop with field-weakening for high-speed regions.
- Parameter configuration through our Windows utility or embedded command set.
- Built-in thermal protection and stall detection.
What's in the Box
- 1 × Robot Dog Joint Module.
- 1 × CAN-terminated cable (300 mm).
- Mechanical drawing and STEP file.
- Sample firmware and Windows tuning utility.
Sampling starts immediately. Production lead time is 4–6 weeks depending on quantity. Contact our engineering team with your target torque, speed and quantity.