WAYINMOTION, with 10+ years in power transmission components, offers 6061-T6 aluminum clamp plates, timing pulleys, gears, couplings, OEM machining, and integrated robot joint modules for humanoids, quadrupeds and collaborative arms.
We design and manufacture precision power transmission components and integrated robot joint modules for automation equipment, CNC machinery, packaging lines and next-generation robotics.
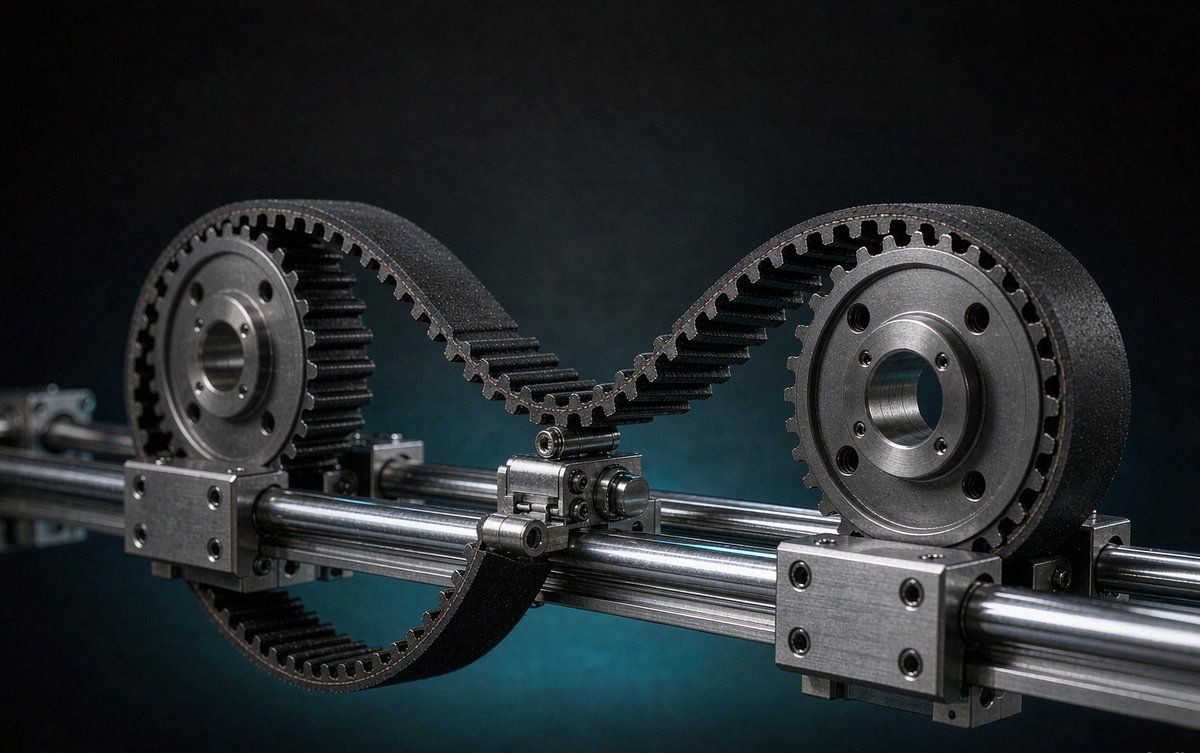
The core function of the timing belt clamp plate is to ensure smooth, accurate and reliable power transmission by maintaining precise belt positioning and stable engagement, while effectively preventing slippage and misalignment.
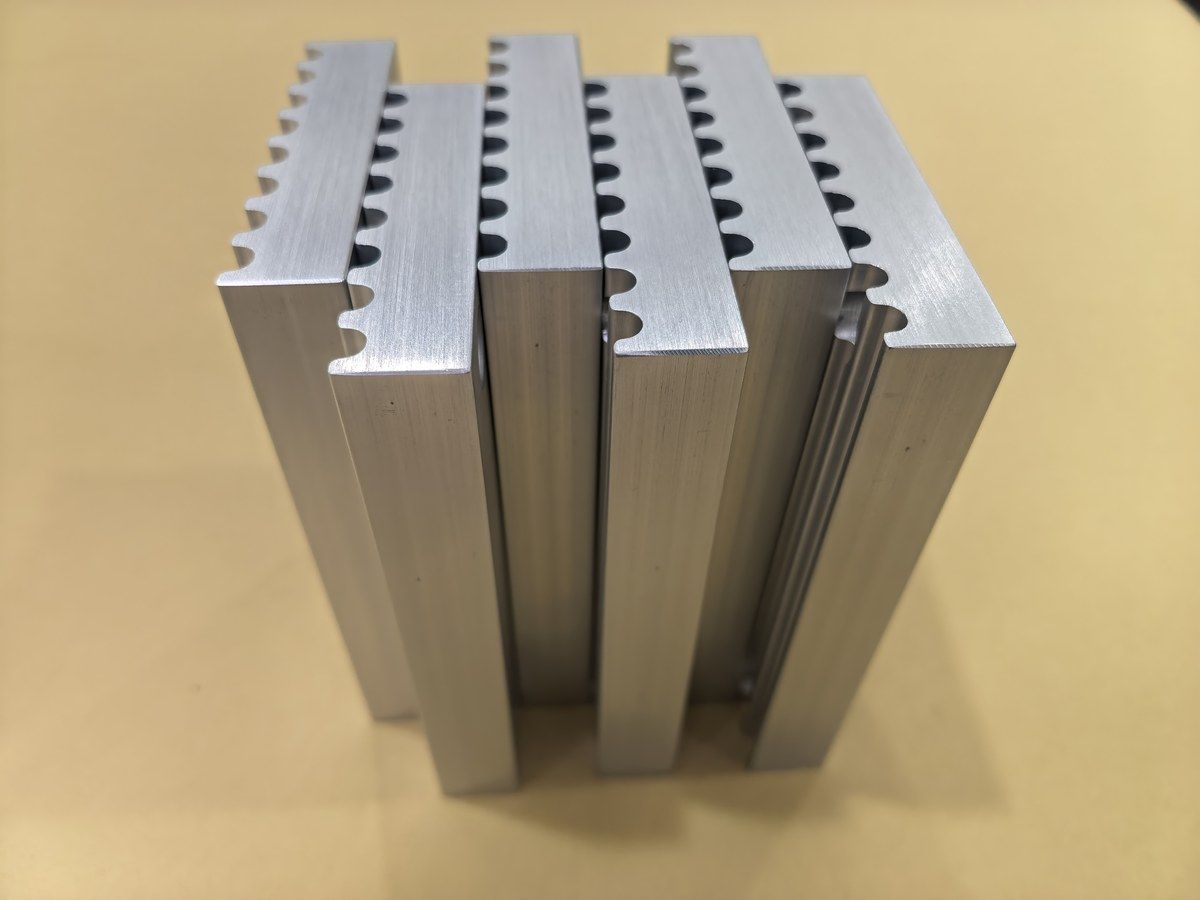
Our clamp plates are CNC-machined from 6061-T6 high-strength aluminum alloy, with hard anodized surfaces for wear and corrosion resistance. Each tooth profile is replicated 1:1 to match standard timing belts, giving you zero-backlash engagement and long service life.
Beyond clamp plates, we supply timing pulleys, locking assemblies, gears, couplings, taper bushes, timing bars, shaft sleeves and OEM custom parts. We also develop integrated robot joint modules combining motor, reducer, encoder and drive for humanoid robots, quadrupeds and collaborative arms.

Own factory with 10+ years of transmission-component manufacturing experience.
6061-T6 aviation-grade aluminum alloy, hard anodized surface, ready to install.
CNC precision machining, accurate hole positions, strict factory inspection.
Special sizes, hole patterns and finishes upon request — send us your drawing.
Standard tooth profiles replicated 1:1 for zero-backlash engagement.
36 standard clamp-plate codes covering XL / L / H / HTD / T / AT profiles.
Regular models in stock; samples and small batches shipped quickly.
Technical selection support, installation guidance and after-sales follow-up.
Precision timing belt clamp plates and matching transmission parts for industrial automation, CNC machinery, packaging lines and more.

Standard and custom clamp plates for open-ended synchronous belts across XL, L, H, HTD, T and AT profiles. CNC-machined from 6061-T6 aluminum with hard anodized surfaces.
A selection of our best-selling and representative sizes. All profiles are available from stock or short lead time.

Pitch 5.08 mm · Belt width 9.5 mm

Pitch 9.525 mm · Belt width 25.4 mm

Pitch 12.7 mm · Belt width 25.4 mm

Pitch 3 mm · Belt width 15 mm

Pitch 5 mm · Belt width 15 mm

Pitch 8 mm · Belt width 20 mm

Pitch 8 mm · Belt width 85 mm

Pitch 14 mm · Belt width 85 mm

Pitch 5 mm · Belt width 25 mm

Pitch 10 mm · Belt width 50 mm

Pitch 5 mm · Belt width 25 mm

Pitch 10 mm · Belt width 32 mm
Material: Aluminum Alloy 6061-T6 · Unit: mm. Click a filter to narrow by belt profile.
| Belt Type | Product Code | Pitch | A | B | S | Ød | F | L | C |
|---|---|---|---|---|---|---|---|---|---|
| XL | XL-025 | 5.08 | 42.5 | 25.5 | 8 | 5.5 | 6 | 6.4 | 3.5 |
| XL | XL-037 | 5.08 | 42.5 | 28.5 | 8 | 5.5 | 6 | 9.5 | 3.5 |
| L | L-050 | 9.525 | 76.6 | 39 | 15 | 9 | 8 | 12.7 | 5 |
| L | L-075 | 9.525 | 76.6 | 45 | 15 | 9 | 8 | 19.1 | 5 |
| L | L-100 | 9.525 | 76.6 | 51.5 | 15 | 9 | 8 | 25.4 | 5 |
| H | H-050 | 12.7 | 106.9 | 45 | 22 | 11 | 10 | 12.7 | 9 |
| H | H-075 | 12.7 | 106.9 | 51 | 22 | 11 | 10 | 19.1 | 9 |
| H | H-100 | 12.7 | 106.9 | 57.5 | 22 | 11 | 10 | 25.4 | 9 |
| HTD | 3M-09 | 3 | 25 | 24 | 5 | 4.5 | 5 | 9 | 2 |
| HTD | 3M-15 | 3 | 25 | 30 | 5 | 4.5 | 5 | 15 | 2 |
| HTD | 5M-09 | 5 | 41.5 | 28 | 8 | 5.5 | 6 | 9 | 3.2 |
| HTD | 5M-15 | 5 | 41.5 | 34 | 8 | 5.5 | 6 | 15 | 3.2 |
| HTD | 5M-25 | 5 | 41.5 | 44 | 8 | 5.5 | 6 | 25 | 3.2 |
| HTD | 8M-20 | 8 | 66 | 45 | 15 | 9 | 8 | 20 | 5 |
| HTD | 8M-30 | 8 | 66 | 55 | 15 | 9 | 8 | 30 | 5 |
| HTD | 8M-50 | 8 | 66 | 75 | 15 | 9 | 8 | 50 | 5 |
| HTD | 8M-85 | 8 | 66 | 110 | 15 | 9 | 8 | 85 | 5 |
| HTD | 14M-40 | 14 | 116 | 71 | 22 | 11 | 10 | 40 | 9 |
| HTD | 14M-55 | 14 | 116 | 86 | 22 | 11 | 10 | 55 | 9 |
| HTD | 14M-85 | 14 | 116 | 116 | 22 | 11 | 10 | 85 | 9 |
| HTD | 14M-115 | 14 | 116 | 146 | 22 | 11 | 10 | 115 | 9 |
| HTD | 14M-170 | 14 | 116 | 201 | 22 | 11 | 10 | 170 | 9 |
| T | T5-10 | 5 | 41.8 | 29 | 8 | 5.5 | 6 | 10 | 3.4 |
| T | T5-16 | 5 | 41.8 | 35 | 8 | 5.5 | 6 | 16 | 3.4 |
| T | T5-25 | 5 | 41.8 | 44 | 8 | 5.5 | 6 | 25 | 3.4 |
| T | T10-16 | 10 | 80 | 41 | 15 | 9 | 8 | 16 | 5 |
| T | T10-25 | 10 | 80 | 50 | 15 | 9 | 8 | 25 | 5 |
| T | T10-32 | 10 | 80 | 57 | 15 | 9 | 8 | 32 | 5 |
| T | T10-50 | 10 | 80 | 75 | 15 | 9 | 8 | 50 | 5 |
| AT | AT5-10 | 5 | 41.8 | 29 | 8 | 5.5 | 6 | 10 | 3.4 |
| AT | AT5-16 | 5 | 41.8 | 35 | 8 | 5.5 | 6 | 16 | 3.4 |
| AT | AT5-25 | 5 | 41.8 | 44 | 8 | 5.5 | 6 | 25 | 3.4 |
| AT | AT10-16 | 10 | 80 | 41 | 15 | 9 | 8 | 16 | 5 |
| AT | AT10-25 | 10 | 80 | 50 | 15 | 9 | 8 | 25 | 5 |
| AT | AT10-32 | 10 | 80 | 57 | 15 | 9 | 8 | 32 | 5 |
| AT | AT10-50 | 10 | 80 | 75 | 15 | 9 | 8 | 50 | 5 |
Motor + reducer + encoder + driver integrated actuators for humanoid robots, quadrupeds and collaborative arms.

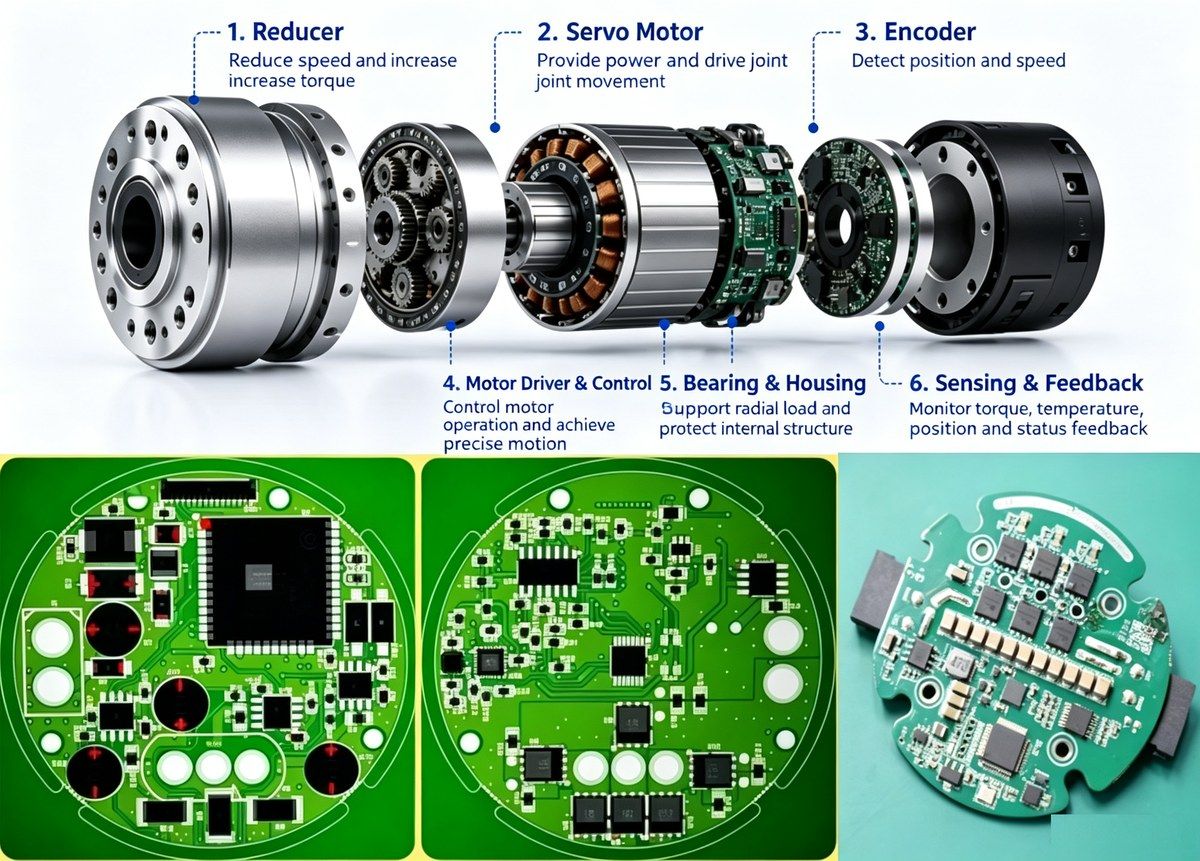
Our integrated joint modules combine frameless torque motor, precision reducer, dual magnetic encoder and FOC drive into a compact, ready-to-use actuator. Designed for high torque density, precise force control and light-weight integration.
Two standard series for different robot sizes and torque requirements. Custom voltage, reducer ratio and mechanical interface available.

≤220 g · 24 V · 3.0 / 6.0 N·m · 10:1 planetary

≤1,500 g · 48 V · 45 / 145 N·m · harmonic ≥100:1
| Parameter | Value |
|---|---|
| Rated voltage | 24 V |
| Voltage range | 20–28 V |
| Rated current | 3.0 A |
| Peak current | 7.0 A |
| Rated output power | ≥70 W |
| Drive mode | FOC |
| Rated torque | 3.0 N·m |
| Max output torque | 6.0 N·m |
| Reduction ratio | 10:1 (planetary) |
| Magnetic encoder | 2 pcs |
| Weight | ≤220 g |
| Rated speed | ≥120 rpm |
| No-load speed | ≥300 rpm |
| Operating temp. | −20 °C ~ +70 °C |
| Parameter | Value |
|---|---|
| Rated voltage | 48 V |
| Voltage range | 24–56 V |
| Rated current | 4.0 A |
| Peak current | 15.0 A |
| Rated output power | ≥141.5 W |
| Drive mode | FOC |
| Rated torque | 45 N·m |
| Max output torque | 145 N·m |
| Reduction ratio | ≥100:1 (harmonic) |
| Magnetic encoder | Dual 24-bit |
| Weight | ≤1,500 g |
| Rated speed | ≥30 rpm |
| No-load speed | ≥45 rpm |
| Operating temp. | −20 °C ~ +70 °C |
No special tools required. Slide, align, tighten and run.

Clean the contact surfaces of the timing belt and clamp plate to remove oil and impurities.

Slide the open belt fully into the toothed grooves for aligned meshing.

Align the mounting holes with your slide or fixture.

Tighten the matched screws evenly to avoid unilateral stress.

Test-run the drive and confirm smooth, jam-free operation.
Trusted across the industries that depend on precise, repeatable linear motion.


Complete your drive system with our range of standard and custom power transmission parts.


From material selection to final inspection, every plate is manufactured for reliable industrial use.
Accurate tooth profiles, hole positions and surface flatness on every part.
6061-T6 aluminum alloy with batch records and incoming material checks.
Dimensional verification, visual inspection and fit check before shipment.
Special lengths, hole patterns, surface finishes and branding upon request.
Industry knowledge, company milestones and new product releases. Click any card to read the full article.
No posts found for this year.
 Engineering
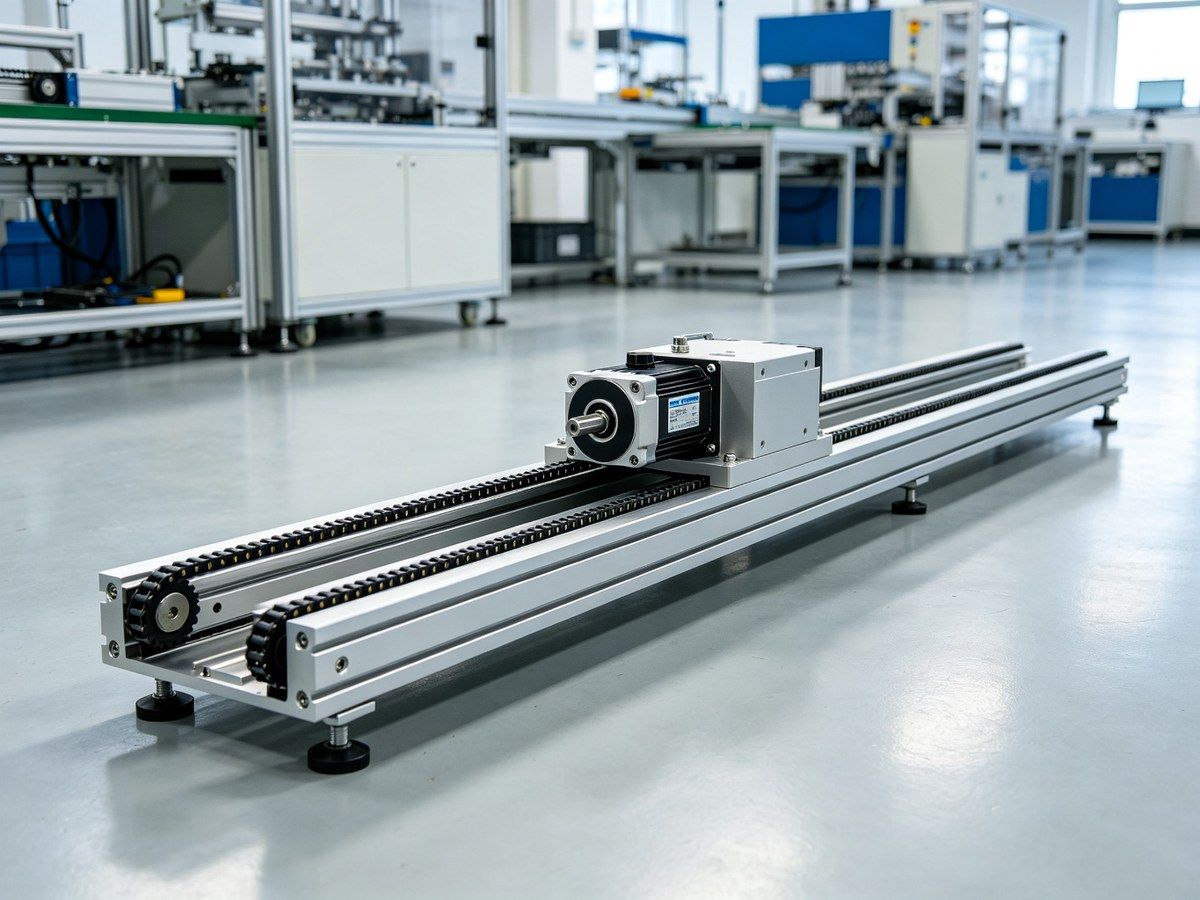
Pitch tolerance, belt profile and load capacity — three parameters that determine whether a clamp plate will hold alignment under continuous duty cycle.
 Robotics
Built-in encoder, harmonic / planetary reducer and FOC drive cut wiring, weight and failure points — a comparison for humanoid and quadruped engineers.
 Material
Strength, machinability, anodizing response and cost — when each alloy makes sense for clamp plates and structural robot parts.
 Milestone
From timing-belt accessories to integrated robot joint modules — a decade of one-stop OEM machining for global B2B customers.
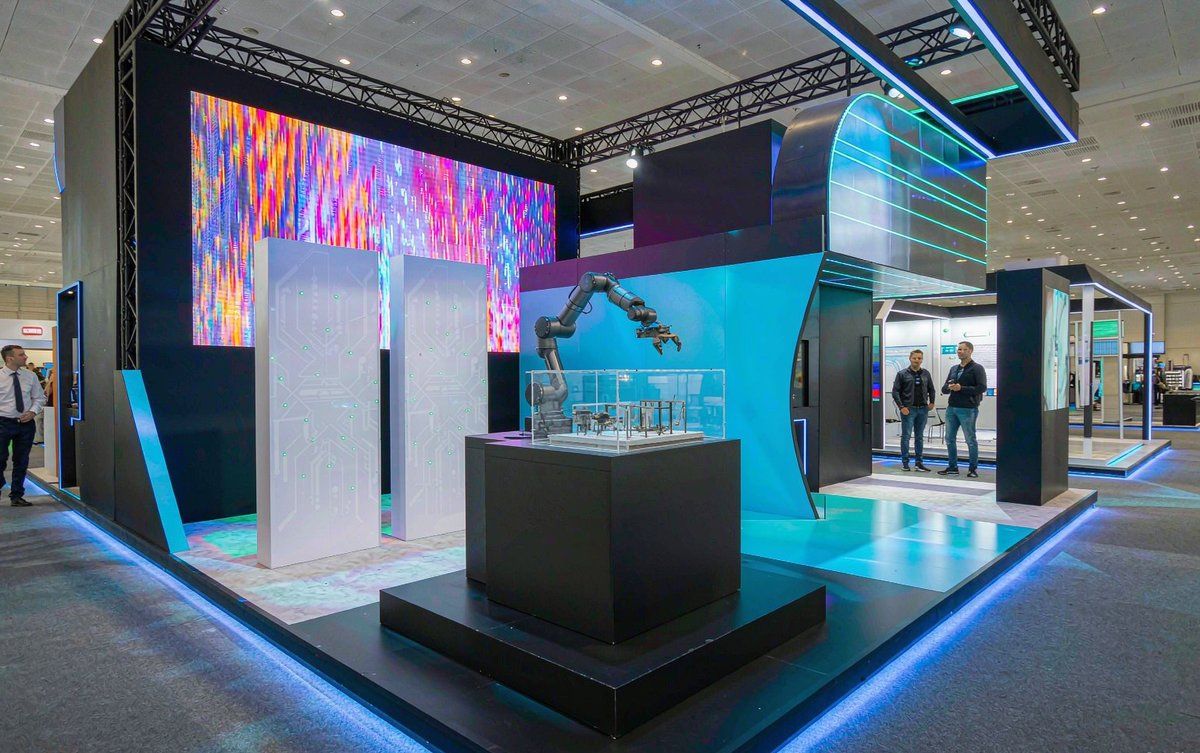 Exhibition
Our team visited the Shenzhen automation and robotics show in late August to track trends in motion components, robot actuators and smart manufacturing.
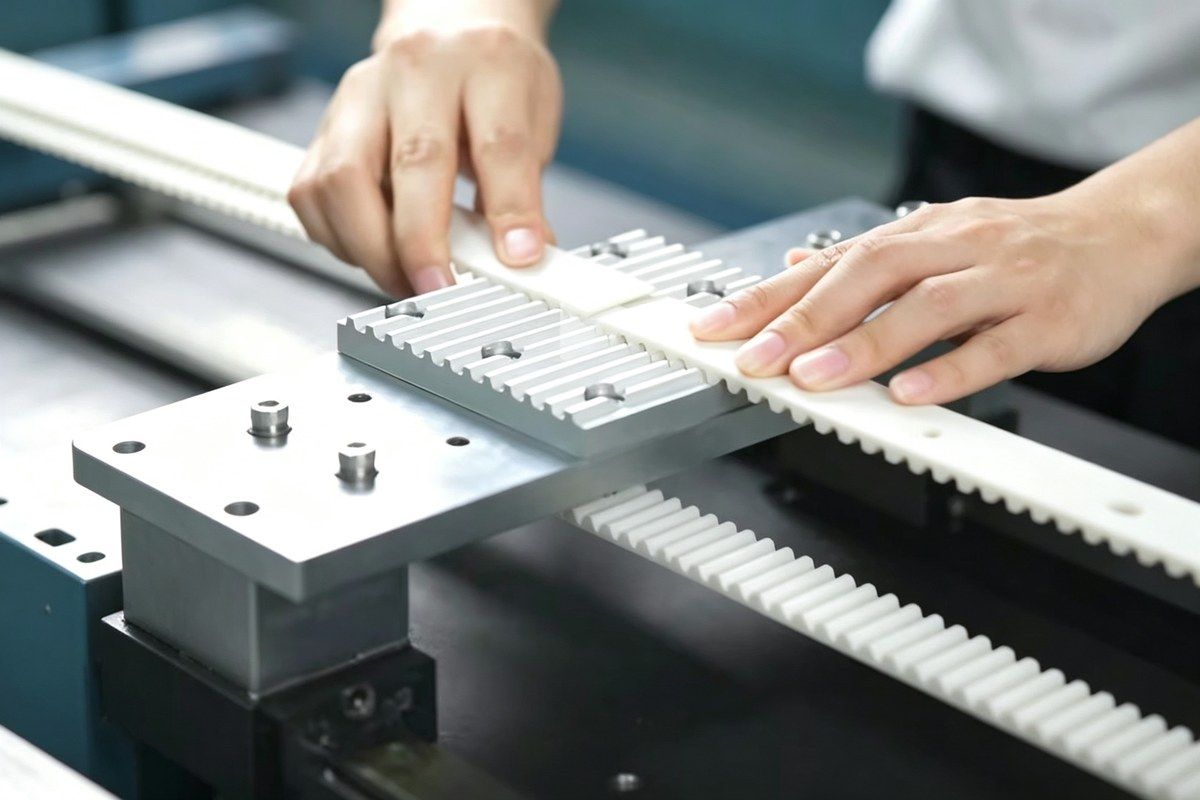 Team
New CNC centers, CMM inspection and dedicated prototyping lines added to support faster lead times on custom OEM projects.
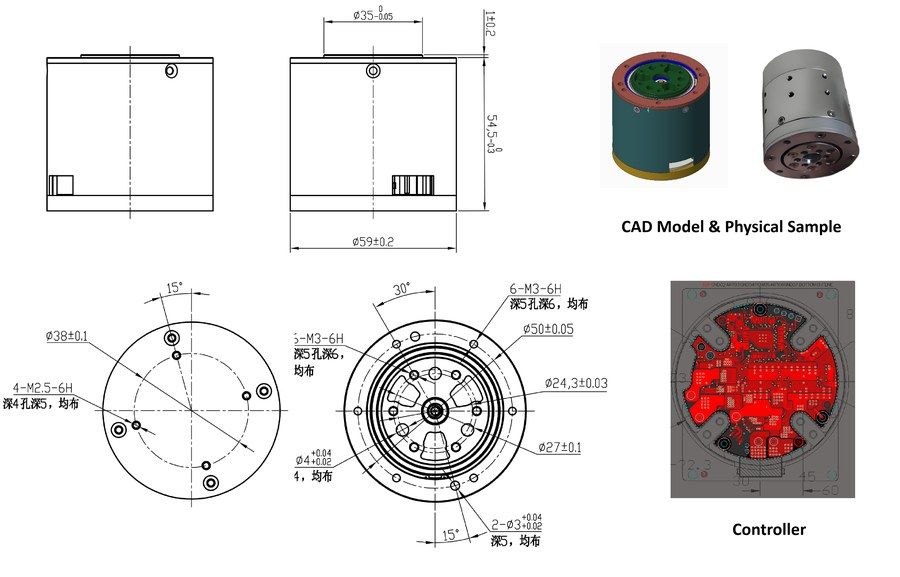 New Release
24 V FOC drive, 10:1 planetary reducer, dual magnetic encoders. Designed for quadruped robot legs where weight and torque density matter most.
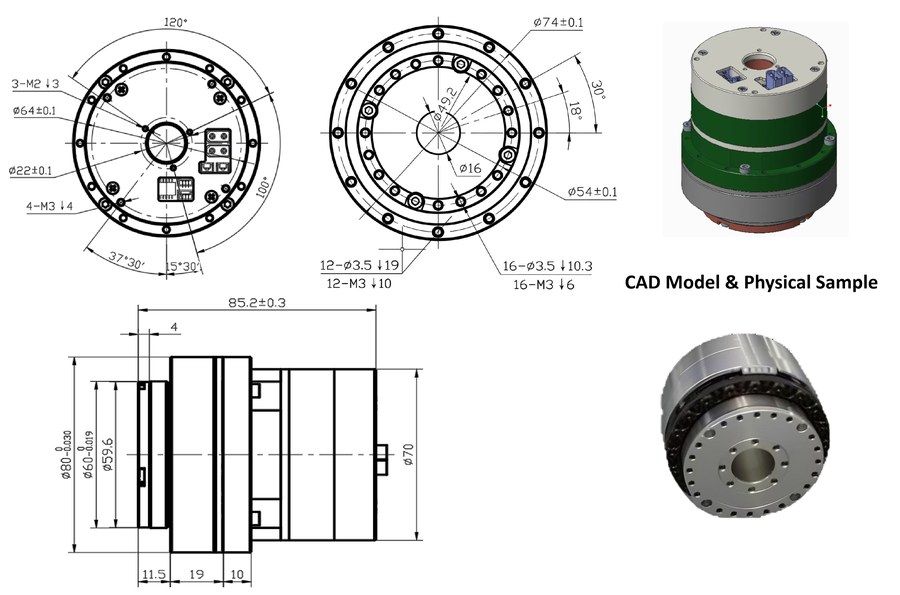 New Release
48 V, ≥100:1 harmonic reducer, dual 24-bit encoders for humanoid joints, collaborative arms and high-precision automation axes.
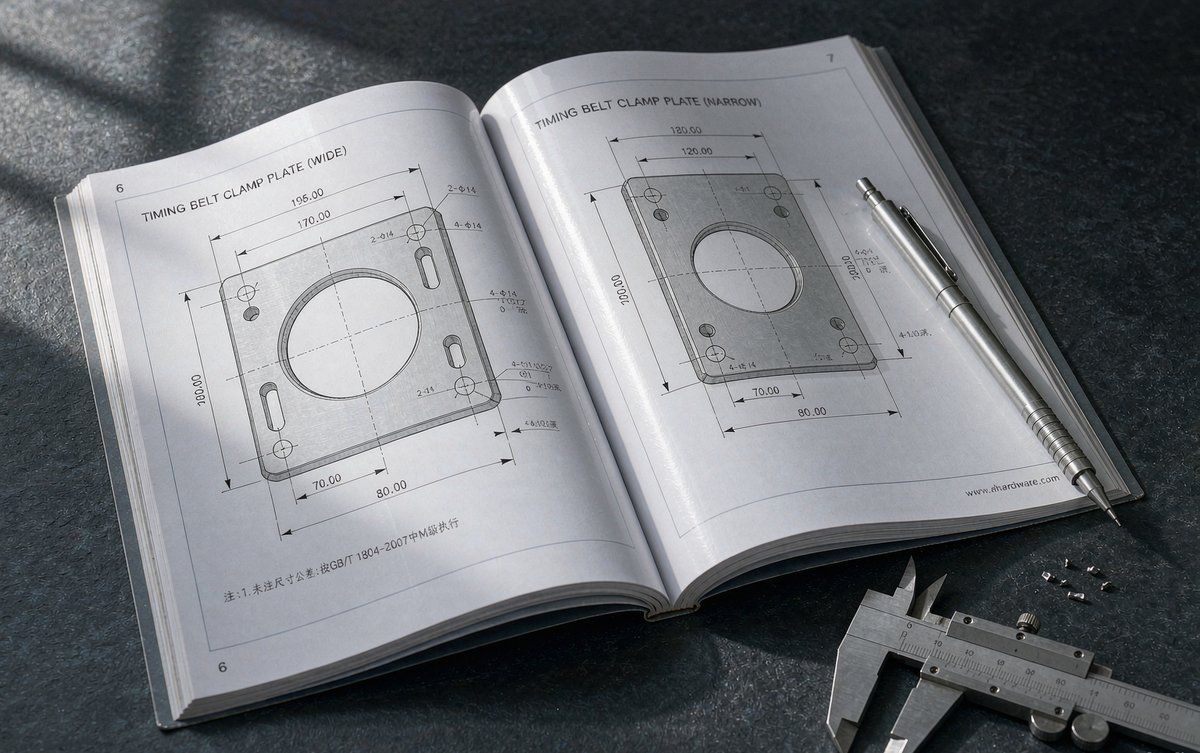 Updated Spec
The latest English catalog covers 36 standard clamp-plate sizes, all 6 belt profiles and the new robot joint module series. Download now.
Tell us your belt type, size and quantity. We reply within 24 hours.
Send your drawing or requirements for a fast, competitive quotation. We support small batch, bulk order and custom OEM projects.
